Đang tải trang
Liên hệ
Sản phẩm cần báo giá theo số lượng, công suất hoặc dự án. Gửi yêu cầu để được tư vấn nhanh.
Tổng quan
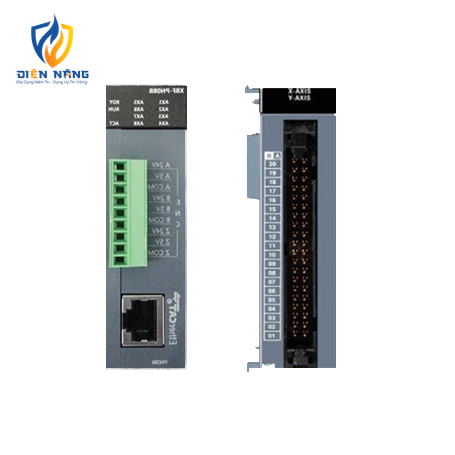
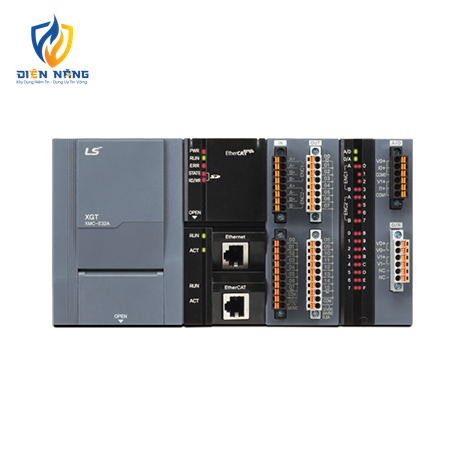
XGT Motion & Positioning Module XGT Motion & Positioning Module Contact us Features XGT Motion Module • 32 axes (master) and 4 axes (virtual) control • EhterCAT CoE supported servo drive • Communication cycle: 1ms • Built-in DI/DO 8 points each and EtherCAT I/O 512 points • Program 2MB • External encoder input 2ch (line drive) • Max. transmission distance: 100m XGT Positioning Module Features (Network type) • XGF-PN8A: Dedicated LS ELECTRIC EtherCAT Network Support (XGT Servo N series) • XGF-PN8B: Standard EtherCAT Network Support(Standard EtherCAT Servo) • Direct connect with servo driver Max 8 • 2~8 axes linear interpolation, 2-axes circular interpolation, 3-axes helical interpolation • Position, speed, and feed control is possible through the various operation • Parameters, the operation data stored in the FRAM (No Battery) • Up to eight different types of CAM data for CAM control • Available for absolute position system (When applying absolute encoder type) XGT Positioning Module Features (Pulse type) • Max 4Axes, Max pulse output 4Mpps • inear/Circular/ellipse/helical interpolation • Asymmetric acceleration and deceleration driving • Speed control, position control, speed/position control, position/speed control, Feed, CAM control • FRAM parameter • XG-PM monitoring, simulation, trace • CAM profile program Specification XGT Motion Module XGT Positioning Module (Network type) ItemXGF-M32E CommunicationEtherCAT (CoE : CANopen over EtherCAT) Number of axisReal32 axes Virtual4axes I/OInput/output 8 points each (built-in) EtherCAT I/O connection available Control period1ms, 2ms, 4ms (same as main task period) Control unitPulse, mm, inch, degree I/OInternalInput 8 points, output 8 points ExternalEtherCAT I/O 4 ea(max. 256 points) Motion ProgramNo. of programMax. 256 ea CapacityMax. 2Mbyte LanguageLD(FB), ST Position data6400 points/all aixs Control methodPosition, Velocity, Torque(Servo drivers support) control, Synchronous control, Interpolation control Range of position/velocity± LREAL, 0 Acc. Dec. processTrapezoid type, S-type (Setting to specify the Jerk at function block) Acc. Dec. time1 ~ 2, 147, 483, 647ms Manual operationJOG operation Torque unitRated torque % designation Encoder inputChannel2 chennels Max. inputMax. 500Kpps Input methodLine drive input (RS-422A IEC specification) Open collector output type encoder Input typeCW/CCW, Pulse/Dir, Phase A/B Max. distance100m Communication cableOver CAT.5 STP(Shielded Twisted-pair) cable Error indicationIndicated by LED Communication status indicationIndicated by LED Occupied point I/OVariable: 16 point, Fixed: 64 point Communication physical layer100BASE-TX Consumable current(mA)900mA Weight122g XGT Positioning Module (Pulse type) ItemXGF-PN8A/PN8BXGF-PN4B Number of axis8 axis4 axis Interpolation2~8 axis linear, 2axis circular, 3axis helical interpolation Control methodPosition, speed, Speed/position, position/speed position/torque, Feed control Setting unitpulse, mm, inch, degree Positioning dataEach axis has 400 data items (Operation step number 1~400). It is available to set with software package or programming. XG5000PortRS-232C, USB DataBasic, expansion, manual, servo parameter, operation data, cam data, command information MonitorOperation, trace, input sort, error information Back-upFRAM(parameter, operation data) no battery PositioningPositoningAbsolute/lncremental method Position address-AbsolutelncrementalSpeed/position, position/speed rangeconversion control mm-214748364.8 ~ 214748364.7(㎛)-214748364.8 ~ 214748364.7(㎛)-214748364.8 ~ 214748364.7(㎛) inch-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647 degree-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647 pulse-2147483648 ~ 2147483647-2147483648 ~ 2147483647-2147483648 ~ 2147483647 Position speedmm0.01 ~ 20000000.00(mm/Min) rangeinch0.001 ~ 2000000.000(inch/Min) degree0.001 ~ 2000000.000(degree/Min) pulse1 ~ 20.000.000 (pulse/Sec) RPM0.1 ~ 100000.0(RPM) Accel/DecelTrapezoidal & S-curve acceleration/deceleration pattern Accel/Decel time1~2.147.483.647ms ManualJog/ MPG/ inching Homing methodMax+Z(Forward), Min+Z(Backward), Near-point+Z(Forward, Backward), Max+near-point+Z(Forward), Min+near-point+Z(Backward), Z(Forward, Backward), near-point(Forward, Backward) The ability to Change speedAbsolute/Percent TorqueRated torque % Absolute position SystemO (Absolute encoder type servo) EncoderChannel2 Channel inputMax. InputMax. 200 Kpps Input methodline-drive input(RS-422A IEC), open collector output type TypeCW/CCW, Pulse/Dir, Phase A/B Connector12 Pin connector Communication Cycle800 ㎲ Max. distance100 m CableSTP(Shielded Twisted pair) cable Error displayLED Operation displayLED Occupied points of I/O64points (Fixed type), 16points (Variable type) Current consumption (mA)500 ㎃ Weight(kg)115 g More Information ItemXGF-PO1HXGF-PO2HXGF-PO3HXGF-PO4H XGF-PD1HXGF-PD2HXGF-PD3HXGF-PD4H Number of axis1 axis2 axis3 axis4 axis Interpolation-Circular, linear, ellipseCircular, linear, helical, ellipse Control methodPosition control, speed control, speed/position control, position/speed control, FEED Positioning dataEach axis has 400 data items (Operation step number 1~400). It is available to set with XG5000 or programming. Configuration ToolXG5000 (Connected with USB or RS-232C Port of CPU module) Data backupFRAM(Parameter, Operation data), Flash memory (CAM Data), No battery Pulse outputXGF-POxH: Open collector, XGF-PDxH: linedriver PositioningPositioning methodAbsolute / Incremental Positionmm-214,748,364.8 ∼ 214,748,364.7(㎛) addressinch-21,474.83648 ∼ 21,474.83647 rangedegree-21,474.83648 ∼ 21,474.83647 pulse-2,147,483,648 ∼ 2,147,483,647 Positionmm0.01 ∼ 20,000,000.00(㎜/min) addressinch0.001 ∼ 2,000,000.000(inch/min) speeddegree0.001 ∼ 2,000,000.000(degree/min) pulse1 ~ 500,000(pulse/sec): Open collector, 1 ~ 4,000,000(pulse/sec): linedriver RPM0.1 ∼ 100,000.0(RPM) Accel/Decel patternTrapezoidal & S-curve acceleration/deceleration Accel/Decel time0~2,147,483,647ms Max. output pulseOpen collector: 500kpps, linedriver: 4Mpps Max. distanceOpen collector: 5m, linedriver: 10m Max. encoder input500kpps Error displayLED Size of cableAWG #24 Occupied points of I/O64 points (Fixed type), 16 points (Variable type) Connection connector40Pin80Pin Current consumption (mA)XGF-PO1H:400mAXGF-PO2H:410mAXGF-PO3H:420mAXGF-PO3H:420mA XGF-PD1H:520mAXGF-PD2H:600mAXGF-PD3H:850mAXGF-PD4H:890mA Weight (kg)120130
| mm | -214748364.8 ~ 214748364.7(㎛) |
|---|---|
| I/O | Input/output 8 points each (built-in) EtherCAT I/O connection available | Internal | Input 8 points, output 8 points |
| RPM | 0.1 ~ 100000.0(RPM) | 0.1 ∼ 100,000.0(RPM) |
| Data | Basic, expansion, manual, servo parameter, operation data, cam data, command information |
| Item | XGF-M32E | XGF-PN8A/PN8B | XGF-PN4B | XGF-PO1H |
| Type | CW/CCW, Pulse/Dir, Phase A/B |
| inch | -21474.83648 ~ 21474.83647 |
| Cable | STP(Shielded Twisted pair) cable |
| input | Max. Input | Max. 200 Kpps |
| pulse | -2147483648 ~ 2147483647 | 1 ~ 20.000.000 (pulse/Sec) | -2,147,483,648 ∼ 2,147,483,647 | 1 ~ 500,000(pulse/sec): Open collector, 1 ~ 4,000,000(pulse/sec): linedriver |
| range | conversion control | inch | 0.001 ~ 2000000.000(inch/Min) | degree | -21,474.83648 ∼ 21,474.83647 |
| speed | degree | 0.001 ∼ 2,000,000.000(degree/min) |
| 2 axis | 3 axis |
| Manual | Jog/ MPG/ inching |
| Torque | Rated torque % |
| Weight | 122g |
| XG5000 | Port | RS-232C, USB |
| degree | -21474.83648 ~ 21474.83647 | 0.001 ~ 2000000.000(degree/Min) |
| Back-up | FRAM(parameter, operation data) no battery |
| Encoder | Channel | 2 Channel |
| Monitor | Operation, trace, input sort, error information |
| Virtual | 4axes |
| address | inch | -21,474.83648 ∼ 21,474.83647 | inch | 0.001 ∼ 2,000,000.000(inch/min) |
| Absolute | lncremental |
| Capacity | Max. 2Mbyte |
| External | EtherCAT I/O 4 ea(max. 256 points) |
| Language | LD(FB), ST |
| Position | mm | -214,748,364.8 ∼ 214,748,364.7(㎛) | mm | 0.01 ∼ 20,000,000.00(㎜/min) |
| XGF-PD1H | XGF-PD2H | 520mAXGF-PD2H:600mAXGF-PD3H:850mAXGF-PD4H:890mA |
| XGF-PD3H | XGF-PD4H |
| XGF-PN8A | Dedicated LS ELECTRIC EtherCAT Network Support (XGT Servo N series) |
| XGF-PN8B | Standard EtherCAT Network Support(Standard EtherCAT Servo) |
| XGF-PO2H | XGF-PO3H |
| Connector | 12 Pin connector |
| Input type | CW/CCW, Pulse/Dir, Phase A/B |
| Max. input | Max. 500Kpps |
| Weight(kg) | 115 g |
| Accel/Decel | Trapezoidal & S-curve acceleration/deceleration |
| Data backup | FRAM(Parameter, Operation data), Flash memory (CAM Data), No battery |
| Positioning | Positoning | Absolute/lncremental | Positioning method | Absolute / Incremental |
| Torque unit | Rated torque % designation |
| Weight (kg) | 120 | 130 |
| Control unit | Pulse, mm, inch, degree |
| Input method | Line drive input (RS-422A IEC specification) Open collector output type encoder | line-drive input(RS-422A IEC), open collector output type |
| Pulse output | XGF-POxH: Open collector, XGF-PDxH: linedriver |
| Setting unit | pulse, mm, inch, degree |
| Communication | EtherCAT (CoE : CANopen over EtherCAT) |
| Encoder input | Channel | 2 chennels |
| Error display | LED |
| Homing method | Max+Z(Forward), Min+Z(Backward), Near-point+Z(Forward, Backward), Max+near-point+Z(Forward), |
| Interpolation | 2~8 axis linear, 2axis circular, 3axis helical interpolation | - |
| Max. distance | 100m | 100 m | Open collector: 5m, linedriver: 10m |
| Position data | 6400 points/all aixs |
| Size of cable | AWG #24 |
| Acc. Dec. time | 1 ~ 2, 147, 483, 647ms |
| Control method | Position, Velocity, Torque(Servo drivers support) control, Synchronous control, Interpolation control | Position, speed, Speed/position, position/speed position/torque, Feed control | Position control, speed control, speed/position control, position/speed control, FEED |
| Control period | 1ms, 2ms, 4ms (same as main task period) |
| Motion Program | No. of program | Max. 256 ea |
| Number of axis | Real | 32 axes | 8 axis | 4 axis | 1 axis |
| Position speed | mm | 0.01 ~ 20000000.00(mm/Min) |
| XGF-PD1H:520mA | XGF-PD2H:600mA |
| XGF-PD3H:850mA | XGF-PD4H:890mA |
| XGF-PO2H:410mA | XGF-PO3H:420mA |
| Thương hiệu | LS Electric |
| Accel/Decel time | 1~2.147.483.647ms | 0~2,147,483,647ms |
| Error indication | Indicated by LED |
| Manual operation | JOG operation |
| Position address | - |
| Positioning data | Each axis has 400 data items (Operation step number 1~400). It is available to set with software package or programming. | Each axis has 400 data items (Operation step number 1~400). It is available to set with XG5000 or programming. |
| Acc. Dec. process | Trapezoid type, S-type |
| Max. output pulse | Open collector: 500kpps, linedriver: 4Mpps |
| Operation display | LED |
| Configuration Tool | XG5000 (Connected with USB or RS-232C Port of CPU module) |
| Max. encoder input | 500kpps |
| Occupied point I/O | Variable: 16 point, Fixed: 64 point |
| Accel/Decel pattern | Trapezoidal & S-curve acceleration/deceleration |
| Communication Cycle | 800 ㎲ |
| Communication cable | Over CAT.5 STP(Shielded Twisted-pair) cable |
| Communication cycle | 1ms |
| Connection connector | 40Pin | 80Pin |
| Pulse outputXGF-POxH | Open collector, XGF-PDxH: linedriver |
| Consumable current(mA) | 900mA |
| Occupied points of I/O | 64points (Fixed type), 16points (Variable type) | 64 points (Fixed type), 16 points (Variable type) |
| Absolute position System | O (Absolute encoder type servo) |
| Current consumption (mA) | 500 ㎃ | XGF-PO1H:400mA |
| Circular, linear, ellipse | Circular, linear, helical, ellipse |
| CommunicationEtherCAT (CoE | CANopen over EtherCAT) |
| Max. transmission distance | 100m |
| Occupied point I/OVariable | 16 point, Fixed: 64 point |
| Range of position/velocity | ± LREAL, 0 |
| Max. distanceOpen collector | 5m, linedriver: 10m |
| The ability to Change speed | Absolute/Percent |
| pulse1 ~ 500,000(pulse/sec) | Open collector, 1 ~ 4,000,000(pulse/sec): linedriver |
| Communication physical layer | 100BASE-TX |
| Communication status indication | Indicated by LED |
| Max. output pulseOpen collector | 500kpps, linedriver: 4Mpps |
| Current consumption (mA)XGF-PO1H | 400mAXGF-PO2H:410mAXGF-PO3H:420mAXGF-PO3H:420mA |
XGT Motion & Positioning Module XGT Motion & Positioning Module Contact us Features XGT Motion Module • 32 axes (master) and 4 axes (virtual) control • EhterCAT CoE supported servo drive • Communication cycle: 1ms • Built-in DI/DO 8 points each and EtherCAT I/O 512 points • Program 2MB • External encoder input 2ch (line drive) • Max. transmission distance: 100m XGT Positioning Module Features (Network type) • XGF-PN8A: Dedicated LS ELECTRIC EtherCAT Network Support (XGT Servo N series) • XGF-PN8B: Standard EtherCAT Network Support(Standard EtherCAT Servo) • Direct connect with servo driver Max 8 • 2~8 axes linear interpolation, 2-axes circular interpolation, 3-axes helical interpolation • Position, speed, and feed control is possible through the various operation • Parameters, the operation data stored in the FRAM (No Battery) • Up to eight different types of CAM data for CAM control • Available for absolute position system (When applying absolute encoder type) XGT Positioning Module Features (Pulse type) • Max 4Axes, Max pulse output 4Mpps • inear/Circular/ellipse/helical interpolation • Asymmetric acceleration and deceleration driving • Speed control, position control, speed/position control, position/speed control, Feed, CAM control • FRAM parameter • XG-PM monitoring, simulation, trace • CAM profile program Specification XGT Motion Module XGT Positioning Module (Network type) ItemXGF-M32E CommunicationEtherCAT (CoE : CANopen over EtherCAT) Number of axisReal32 axes Virtual4axes I/OInput/output 8 points each (built-in) EtherCAT I/O connection available Control period1ms, 2ms, 4ms (same as main task period) Control unitPulse, mm, inch, degree I/OInternalInput 8 points, output 8 points ExternalEtherCAT I/O 4 ea(max. 256 points) Motion ProgramNo. of programMax. 256 ea CapacityMax. 2Mbyte LanguageLD(FB), ST Position data6400 points/all aixs Control methodPosition, Velocity, Torque(Servo drivers support) control, Synchronous control, Interpolation control Range of position/velocity± LREAL, 0 Acc. Dec. processTrapezoid type, S-type (Setting to specify the Jerk at function block) Acc. Dec. time1 ~ 2, 147, 483, 647ms Manual operationJOG operation Torque unitRated torque % designation Encoder inputChannel2 chennels Max. inputMax. 500Kpps Input methodLine drive input (RS-422A IEC specification) Open collector output type encoder Input typeCW/CCW, Pulse/Dir, Phase A/B Max. distance100m Communication cableOver CAT.5 STP(Shielded Twisted-pair) cable Error indicationIndicated by LED Communication status indicationIndicated by LED Occupied point I/OVariable: 16 point, Fixed: 64 point Communication physical layer100BASE-TX Consumable current(mA)900mA Weight122g XGT Positioning Module (Pulse type) ItemXGF-PN8A/PN8BXGF-PN4B Number of axis8 axis4 axis Interpolation2~8 axis linear, 2axis circular, 3axis helical interpolation Control methodPosition, speed, Speed/position, position/speed position/torque, Feed control Setting unitpulse, mm, inch, degree Positioning dataEach axis has 400 data items (Operation step number 1~400). It is available to set with software package or programming. XG5000PortRS-232C, USB DataBasic, expansion, manual, servo parameter, operation data, cam data, command information MonitorOperation, trace, input sort, error information Back-upFRAM(parameter, operation data) no battery PositioningPositoningAbsolute/lncremental method Position address-AbsolutelncrementalSpeed/position, position/speed rangeconversion control mm-214748364.8 ~ 214748364.7(㎛)-214748364.8 ~ 214748364.7(㎛)-214748364.8 ~ 214748364.7(㎛) inch-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647 degree-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647-21474.83648 ~ 21474.83647 pulse-2147483648 ~ 2147483647-2147483648 ~ 2147483647-2147483648 ~ 2147483647 Position speedmm0.01 ~ 20000000.00(mm/Min) rangeinch0.001 ~ 2000000.000(inch/Min) degree0.001 ~ 2000000.000(degree/Min) pulse1 ~ 20.000.000 (pulse/Sec) RPM0.1 ~ 100000.0(RPM) Accel/DecelTrapezoidal & S-curve acceleration/deceleration pattern Accel/Decel time1~2.147.483.647ms ManualJog/ MPG/ inching Homing methodMax+Z(Forward), Min+Z(Backward), Near-point+Z(Forward, Backward), Max+near-point+Z(Forward), Min+near-point+Z(Backward), Z(Forward, Backward), near-point(Forward, Backward) The ability to Change speedAbsolute/Percent TorqueRated torque % Absolute position SystemO (Absolute encoder type servo) EncoderChannel2 Channel inputMax. InputMax. 200 Kpps Input methodline-drive input(RS-422A IEC), open collector output type TypeCW/CCW, Pulse/Dir, Phase A/B Connector12 Pin connector Communication Cycle800 ㎲ Max. distance100 m CableSTP(Shielded Twisted pair) cable Error displayLED Operation displayLED Occupied points of I/O64points (Fixed type), 16points (Variable type) Current consumption (mA)500 ㎃ Weight(kg)115 g More Information ItemXGF-PO1HXGF-PO2HXGF-PO3HXGF-PO4H XGF-PD1HXGF-PD2HXGF-PD3HXGF-PD4H Number of axis1 axis2 axis3 axis4 axis Interpolation-Circular, linear, ellipseCircular, linear, helical, ellipse Control methodPosition control, speed control, speed/position control, position/speed control, FEED Positioning dataEach axis has 400 data items (Operation step number 1~400). It is available to set with XG5000 or programming. Configuration ToolXG5000 (Connected with USB or RS-232C Port of CPU module) Data backupFRAM(Parameter, Operation data), Flash memory (CAM Data), No battery Pulse outputXGF-POxH: Open collector, XGF-PDxH: linedriver PositioningPositioning methodAbsolute / Incremental Positionmm-214,748,364.8 ∼ 214,748,364.7(㎛) addressinch-21,474.83648 ∼ 21,474.83647 rangedegree-21,474.83648 ∼ 21,474.83647 pulse-2,147,483,648 ∼ 2,147,483,647 Positionmm0.01 ∼ 20,000,000.00(㎜/min) addressinch0.001 ∼ 2,000,000.000(inch/min) speeddegree0.001 ∼ 2,000,000.000(degree/min) pulse1 ~ 500,000(pulse/sec): Open collector, 1 ~ 4,000,000(pulse/sec): linedriver RPM0.1 ∼ 100,000.0(RPM) Accel/Decel patternTrapezoidal & S-curve acceleration/deceleration Accel/Decel time0~2,147,483,647ms Max. output pulseOpen collector: 500kpps, linedriver: 4Mpps Max. distanceOpen collector: 5m, linedriver: 10m Max. encoder input500kpps Error displayLED Size of cableAWG #24 Occupied points of I/O64 points (Fixed type), 16 points (Variable type) Connection connector40Pin80Pin Current consumption (mA)XGF-PO1H:400mAXGF-PO2H:410mAXGF-PO3H:420mAXGF-PO3H:420mA XGF-PD1H:520mAXGF-PD2H:600mAXGF-PD3H:850mAXGF-PD4H:890mA Weight (kg)120130
Nhận báo giá tốt nhất
Nhận báo giá tốt nhất