Đang tải trang
Liên hệ
Sản phẩm cần báo giá theo số lượng, công suất hoặc dự án. Gửi yêu cầu để được tư vấn nhanh.
Tổng quan
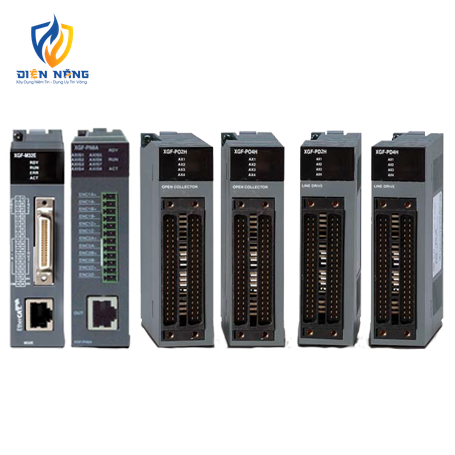
XGB Motion & Positioning module Contact us Features XGB Positioning Module (Network type) • Direct connection with servo driver Max 8 • 2~8 axes linear interpolation, 2-axes circular interpolation, 3-axes helical interpolation • Position, speed, and feed control is possible through various operations • Operation data stored in the FRAM (No battery) • Up to eight different types of CAM data for CAM control • Available for absolute position system (When applying an absolute encoder) XGB Positioning Module (Pulse type) • Max 2Axes, Max pulse output 4Mpps • inear/Circular interpolation • Asymmetric acceleration and deceleration driving • Speed control, position control, speed/position control, position/speed control • XG 5000 monitoring, simulation, trace Specification XGB Positioning Module (Network type) XGB Positioning Module (Pulse type) ItemsPN04BPN08B No. of control axis48 Interpolation function2~4(8) axes linear interpolation, 2 axes circular interpolation, 3 axes helical interpolation Control methodPosition control, Speed control, Speed/Position control, Position/Speed control, Position/Torque Control, Feed control Control unitPulse, ㎜, inch, degree Positioning dataEach axis can have up to 400 operation data .(Operation step number : 1 ∼ 400) Available to set with XG-PM or program XG-PMConnectionRS-232C port of CPU module or USB Setting dataCommon, Basic, Extended, Servo parameter, Operation data, Cam data, Command information MonitorOperation information, Trace, Input terminal information, Error information Back-upSave the parameter, operation data in MRAM ROM (No need of Battery) POSITIONINGPositioning methodAbsolute method/Incremental method Position address rangeAbsoluteIncrementalSpeed/Position, Position/Speed Switching control ㎜-214748364.8∼ 214748364.7(㎛)-214748364.8∼ 214748364.7(㎛)-214748364.8∼ 214748364.7(㎛) Inch-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647 degree-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647 pulse-2147483648 ∼ 2147483647-2147483648 ∼ 2147483647-2147483648 ∼ 2147483647 Speed range㎜0.01 ∼ 20000000.00(㎜/min) Inch0.001 ∼ 2000000.000(Inch/min) degree0.001 ∼ 2000000.000(degree/min) pulse1 ~ 20,000,000(pulse/SEC) rpm0.1 ∼ 100000.0(RPM) Acc./Dec. processTrapezoid type, S-type Acc./Dec. time1 ∼ 2,147,483,647 ㎳ selection is available from 4 types of acceleration/deceleration pattern Manual OperationJog Operation, MPG Operation, Inching Operation Homing methodRefer to the method supported by the servo driver Speed change functionSpeed change (Percent/Absolute value) Torque unitRated torque % designation Absolute position systemAvailable (when using absolute encoder type servo driver) External Encoder inputChannel1 channel Max. Input200 kpps Input formLine drive input (RS-422A IEC specification), open collector output type encoder Input typeCW/CCW, PULSE/DIR, Phase A/B Connection connector9-point connector External command signalInput point3Point(Input signal A,B,Z) Input specificationSame as Input specification of external encoder(5V,24V) Connector9Point connector(input terminal of external encoder shared) Communication Period1ms Max. transmission distance100m Communication cableOver CAT.5 STP (Shielded Twisted-pair) cable Error indicationIndicated by LED Communication status indicationIndicated by LED Consumable current510mA Weight115g More Information ItemsXBF-PD02A No. of control axis2 Interpolation function2 axes linear interpolation, 2 axes circular interpolation Control methodPosition control, Speed control, Speed/Position control, Position/Speed control, Control unitPulse Positioning data150 data area for each axis (operation step number 1 ∼ 150) Can be set by parameter, dedicated monitor window, program Monitoring windowConnectionRS-232C port or USB of basic unit Setting dataBasic, home/manual, common, I/O signal parameter, operation data, command information MonitorOperating information, input signal information, error information Back-upSaves parameter, operation data at flash memory (battery is not necessary) POSITIONINGCoordinateAbsolute coordinate/Incremental coordinate Position address range-2,147,483,648 ∼ 2,147,483,647(pulse) Speed range1 ∼ 2,000,000pps(1pps unit) Acceleration/deceleration processTrapezoid type Acceleration/deceleration time0 ∼ 65,535 ㎳, selection available from 4 types of acceleration/deceleration pattern Manual OperationJOG operation / MPG operation / Inching operation Homing methodDOG+HOME(Off), DOG+HOME(On), DOG, upper-lower limit + HOME, upper-lower limit Speed change functionSpeed change (Percent/Absolute value) External EncoderChannel1 channel Max. Inputmax 200 kpps Input formLin driver input(RS-422A IEC standard) Input typeCW/CCW, PLS/DIR, Phase A/B(4 multiplication) Max. connection distance10 m Error indicationIndicated by LED Connection connector40 Pin connector I/O share pointFixed type: 64 points Consumable current500㎃(DC 5V) Weight65g
| rpm | 0.1 ∼ 100000.0(RPM) |
|---|---|
| ㎜ | -214748364.8∼ 214748364.7(㎛) |
| Inch | -21474.83648 ∼ 21474.83647 | 0.001 ∼ 2000000.000(Inch/min) |
| Items | PN04B | PN08B | XBF-PD02A |
| XG-PM | Connection | RS-232C port of CPU module or USB |
| pulse | -2147483648 ∼ 2147483647 | 1 ~ 20,000,000(pulse/SEC) |
| Weight | 115g | 65g |
| degree | -21474.83648 ∼ 21474.83647 | 0.001 ∼ 2000000.000(degree/min) |
| Back-up | Save the parameter, operation data in MRAM ROM (No need of Battery) | Saves parameter, operation data at flash memory (battery is not necessary) |
| Monitor | Operation information, Trace, Input terminal information, Error information | Operating information, input signal information, error information |
| Connector | 9Point connector(input terminal of external encoder shared) |
| Input form | Line drive input (RS-422A IEC specification), open collector output type encoder | Lin driver input(RS-422A IEC standard) |
| Input type | CW/CCW, PULSE/DIR, Phase A/B | CW/CCW, PLS/DIR, Phase A/B(4 multiplication) |
| Max. Input | 200 kpps | max 200 kpps |
| Incremental | Speed/Position, Position/Speed Switching control |
| POSITIONING | Positioning method | Absolute method/Incremental method | Coordinate | Absolute coordinate/Incremental coordinate |
| Speed range | ㎜ | 0.01 ∼ 20000000.00(㎜/min) | 1 ∼ 2,000,000pps(1pps unit) |
| Torque unit | Rated torque % designation |
| Control unit | Pulse, ㎜, inch, degree |
| Setting data | Common, Basic, Extended, Servo parameter, Operation data, Cam data, Command information | Basic, home/manual, common, I/O signal parameter, operation data, command information |
| Homing method | Refer to the method supported by the servo driver | DOG+HOME(Off), DOG+HOME(On), DOG, upper-lower limit + HOME, upper-lower limit |
| Acc./Dec. time | 1 ∼ 2,147,483,647 ㎳ |
| Control method | Position control, Speed control, Speed/Position control, Position/Speed control, Position/Torque Control, Feed control |
| I/O share point | Fixed type: 64 points |
| Thương hiệu | LS Electric |
| Error indication | Indicated by LED |
| External Encoder | Channel | 1 channel |
| Manual Operation | Jog Operation, MPG Operation, Inching Operation | JOG operation / MPG operation / Inching operation |
| Positioning data | Each axis can have up to 400 operation data .(Operation step number : 1 ∼ 400) | 150 data area for each axis (operation step number 1 ∼ 150) |
| Acc./Dec. process | Trapezoid type, S-type |
| Monitoring window | Connection | RS-232C port or USB of basic unit |
| Consumable current | 510mA | 500㎃(DC 5V) |
| Communication cable | Over CAT.5 STP (Shielded Twisted-pair) cable |
| Input specification | Same as Input specification of external encoder(5V,24V) |
| No. of control axis | 4 | 8 | 2 |
| Communication Period | 1ms |
| Connection connector | 9-point connector | 40 Pin connector |
| Speed change function | Speed change (Percent/Absolute value) |
| External Encoder input | Channel | 1 channel |
| Interpolation function | 2~4(8) axes linear interpolation, 2 axes circular interpolation, 3 axes helical interpolation | 2 axes linear interpolation, 2 axes circular interpolation |
| Position address range | Absolute | -2,147,483,648 ∼ 2,147,483,647(pulse) |
| External command signal | Input point | 3Point(Input signal A,B,Z) |
| Absolute position system | Available (when using absolute encoder type servo driver) |
| Max. connection distance | 10 m |
| I/O share pointFixed type | 64 points |
| Max. transmission distance | 100m |
| Acceleration/deceleration time | 0 ∼ 65,535 ㎳, selection available from 4 types of acceleration/deceleration pattern |
| Communication status indication | Indicated by LED |
| Acceleration/deceleration process | Trapezoid type |
XGB Motion & Positioning module Contact us Features XGB Positioning Module (Network type) • Direct connection with servo driver Max 8 • 2~8 axes linear interpolation, 2-axes circular interpolation, 3-axes helical interpolation • Position, speed, and feed control is possible through various operations • Operation data stored in the FRAM (No battery) • Up to eight different types of CAM data for CAM control • Available for absolute position system (When applying an absolute encoder) XGB Positioning Module (Pulse type) • Max 2Axes, Max pulse output 4Mpps • inear/Circular interpolation • Asymmetric acceleration and deceleration driving • Speed control, position control, speed/position control, position/speed control • XG 5000 monitoring, simulation, trace Specification XGB Positioning Module (Network type) XGB Positioning Module (Pulse type) ItemsPN04BPN08B No. of control axis48 Interpolation function2~4(8) axes linear interpolation, 2 axes circular interpolation, 3 axes helical interpolation Control methodPosition control, Speed control, Speed/Position control, Position/Speed control, Position/Torque Control, Feed control Control unitPulse, ㎜, inch, degree Positioning dataEach axis can have up to 400 operation data .(Operation step number : 1 ∼ 400) Available to set with XG-PM or program XG-PMConnectionRS-232C port of CPU module or USB Setting dataCommon, Basic, Extended, Servo parameter, Operation data, Cam data, Command information MonitorOperation information, Trace, Input terminal information, Error information Back-upSave the parameter, operation data in MRAM ROM (No need of Battery) POSITIONINGPositioning methodAbsolute method/Incremental method Position address rangeAbsoluteIncrementalSpeed/Position, Position/Speed Switching control ㎜-214748364.8∼ 214748364.7(㎛)-214748364.8∼ 214748364.7(㎛)-214748364.8∼ 214748364.7(㎛) Inch-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647 degree-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647-21474.83648 ∼ 21474.83647 pulse-2147483648 ∼ 2147483647-2147483648 ∼ 2147483647-2147483648 ∼ 2147483647 Speed range㎜0.01 ∼ 20000000.00(㎜/min) Inch0.001 ∼ 2000000.000(Inch/min) degree0.001 ∼ 2000000.000(degree/min) pulse1 ~ 20,000,000(pulse/SEC) rpm0.1 ∼ 100000.0(RPM) Acc./Dec. processTrapezoid type, S-type Acc./Dec. time1 ∼ 2,147,483,647 ㎳ selection is available from 4 types of acceleration/deceleration pattern Manual OperationJog Operation, MPG Operation, Inching Operation Homing methodRefer to the method supported by the servo driver Speed change functionSpeed change (Percent/Absolute value) Torque unitRated torque % designation Absolute position systemAvailable (when using absolute encoder type servo driver) External Encoder inputChannel1 channel Max. Input200 kpps Input formLine drive input (RS-422A IEC specification), open collector output type encoder Input typeCW/CCW, PULSE/DIR, Phase A/B Connection connector9-point connector External command signalInput point3Point(Input signal A,B,Z) Input specificationSame as Input specification of external encoder(5V,24V) Connector9Point connector(input terminal of external encoder shared) Communication Period1ms Max. transmission distance100m Communication cableOver CAT.5 STP (Shielded Twisted-pair) cable Error indicationIndicated by LED Communication status indicationIndicated by LED Consumable current510mA Weight115g More Information ItemsXBF-PD02A No. of control axis2 Interpolation function2 axes linear interpolation, 2 axes circular interpolation Control methodPosition control, Speed control, Speed/Position control, Position/Speed control, Control unitPulse Positioning data150 data area for each axis (operation step number 1 ∼ 150) Can be set by parameter, dedicated monitor window, program Monitoring windowConnectionRS-232C port or USB of basic unit Setting dataBasic, home/manual, common, I/O signal parameter, operation data, command information MonitorOperating information, input signal information, error information Back-upSaves parameter, operation data at flash memory (battery is not necessary) POSITIONINGCoordinateAbsolute coordinate/Incremental coordinate Position address range-2,147,483,648 ∼ 2,147,483,647(pulse) Speed range1 ∼ 2,000,000pps(1pps unit) Acceleration/deceleration processTrapezoid type Acceleration/deceleration time0 ∼ 65,535 ㎳, selection available from 4 types of acceleration/deceleration pattern Manual OperationJOG operation / MPG operation / Inching operation Homing methodDOG+HOME(Off), DOG+HOME(On), DOG, upper-lower limit + HOME, upper-lower limit Speed change functionSpeed change (Percent/Absolute value) External EncoderChannel1 channel Max. Inputmax 200 kpps Input formLin driver input(RS-422A IEC standard) Input typeCW/CCW, PLS/DIR, Phase A/B(4 multiplication) Max. connection distance10 m Error indicationIndicated by LED Connection connector40 Pin connector I/O share pointFixed type: 64 points Consumable current500㎃(DC 5V) Weight65g
Nhận báo giá tốt nhất
Nhận báo giá tốt nhất